A modular Mars rover
Chassis and suspension interfaces built around team integration.
In progress · Fall 2026
Harvard Undergraduate Robotics Club
Overview
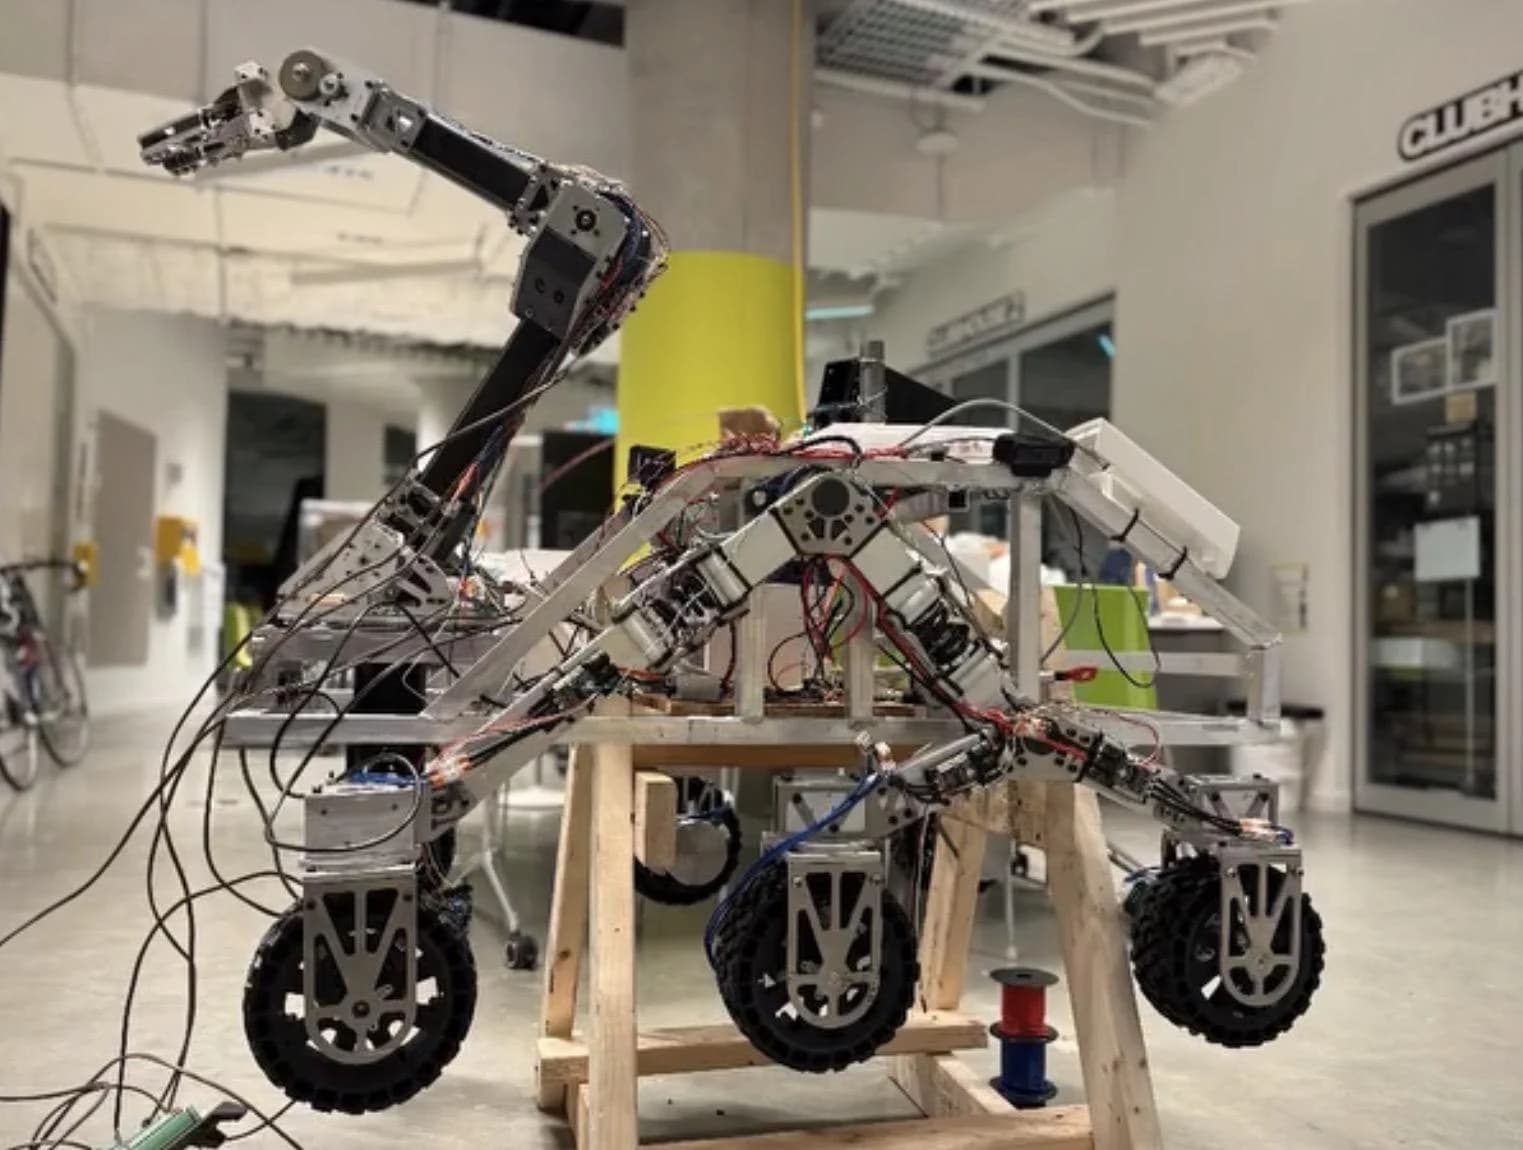
I am working on chassis and suspension for a four-wheel-drive Mars rover platform with independently motor-actuated wheel modules in a semi-swerve layout and a rear differential bar.
My work so far includes initial sketches for the base chassis and wheel-module interfaces, plus research into a modular architecture that makes mounting, disassembly, and iteration easier as the arm, science, and electrical subteams integrate their systems.
Design around the interfaces
A rover chassis is shared infrastructure for multiple subteams. Modular connections are a central design question: how can the wheel modules, chassis, and other systems be integrated and revised without forcing every team to start over?
Current stage
This project is in preliminary design and sketch development. The second gallery image shows the chassis and suspension direction our team is working toward. I’m using that reference as we develop the modular chassis and wheel-module interfaces for our rover.
Gallery
Rover reference photograph from the source portfolio; contextual imagery
Reference for the chassis and suspension configuration our team is working toward
Keep exploring
LeBot James